Zhitu provides a complete measurement and control system.
Test — UWB Positioning Control — Follow Strategy, Motor Control
UWB Frequency
Scope of Work
Covering Angle
UWB Follow System
Complete UWB Follow System: From Use Cases to Core Components, Specifications to Real-World Performance.
Use Cases
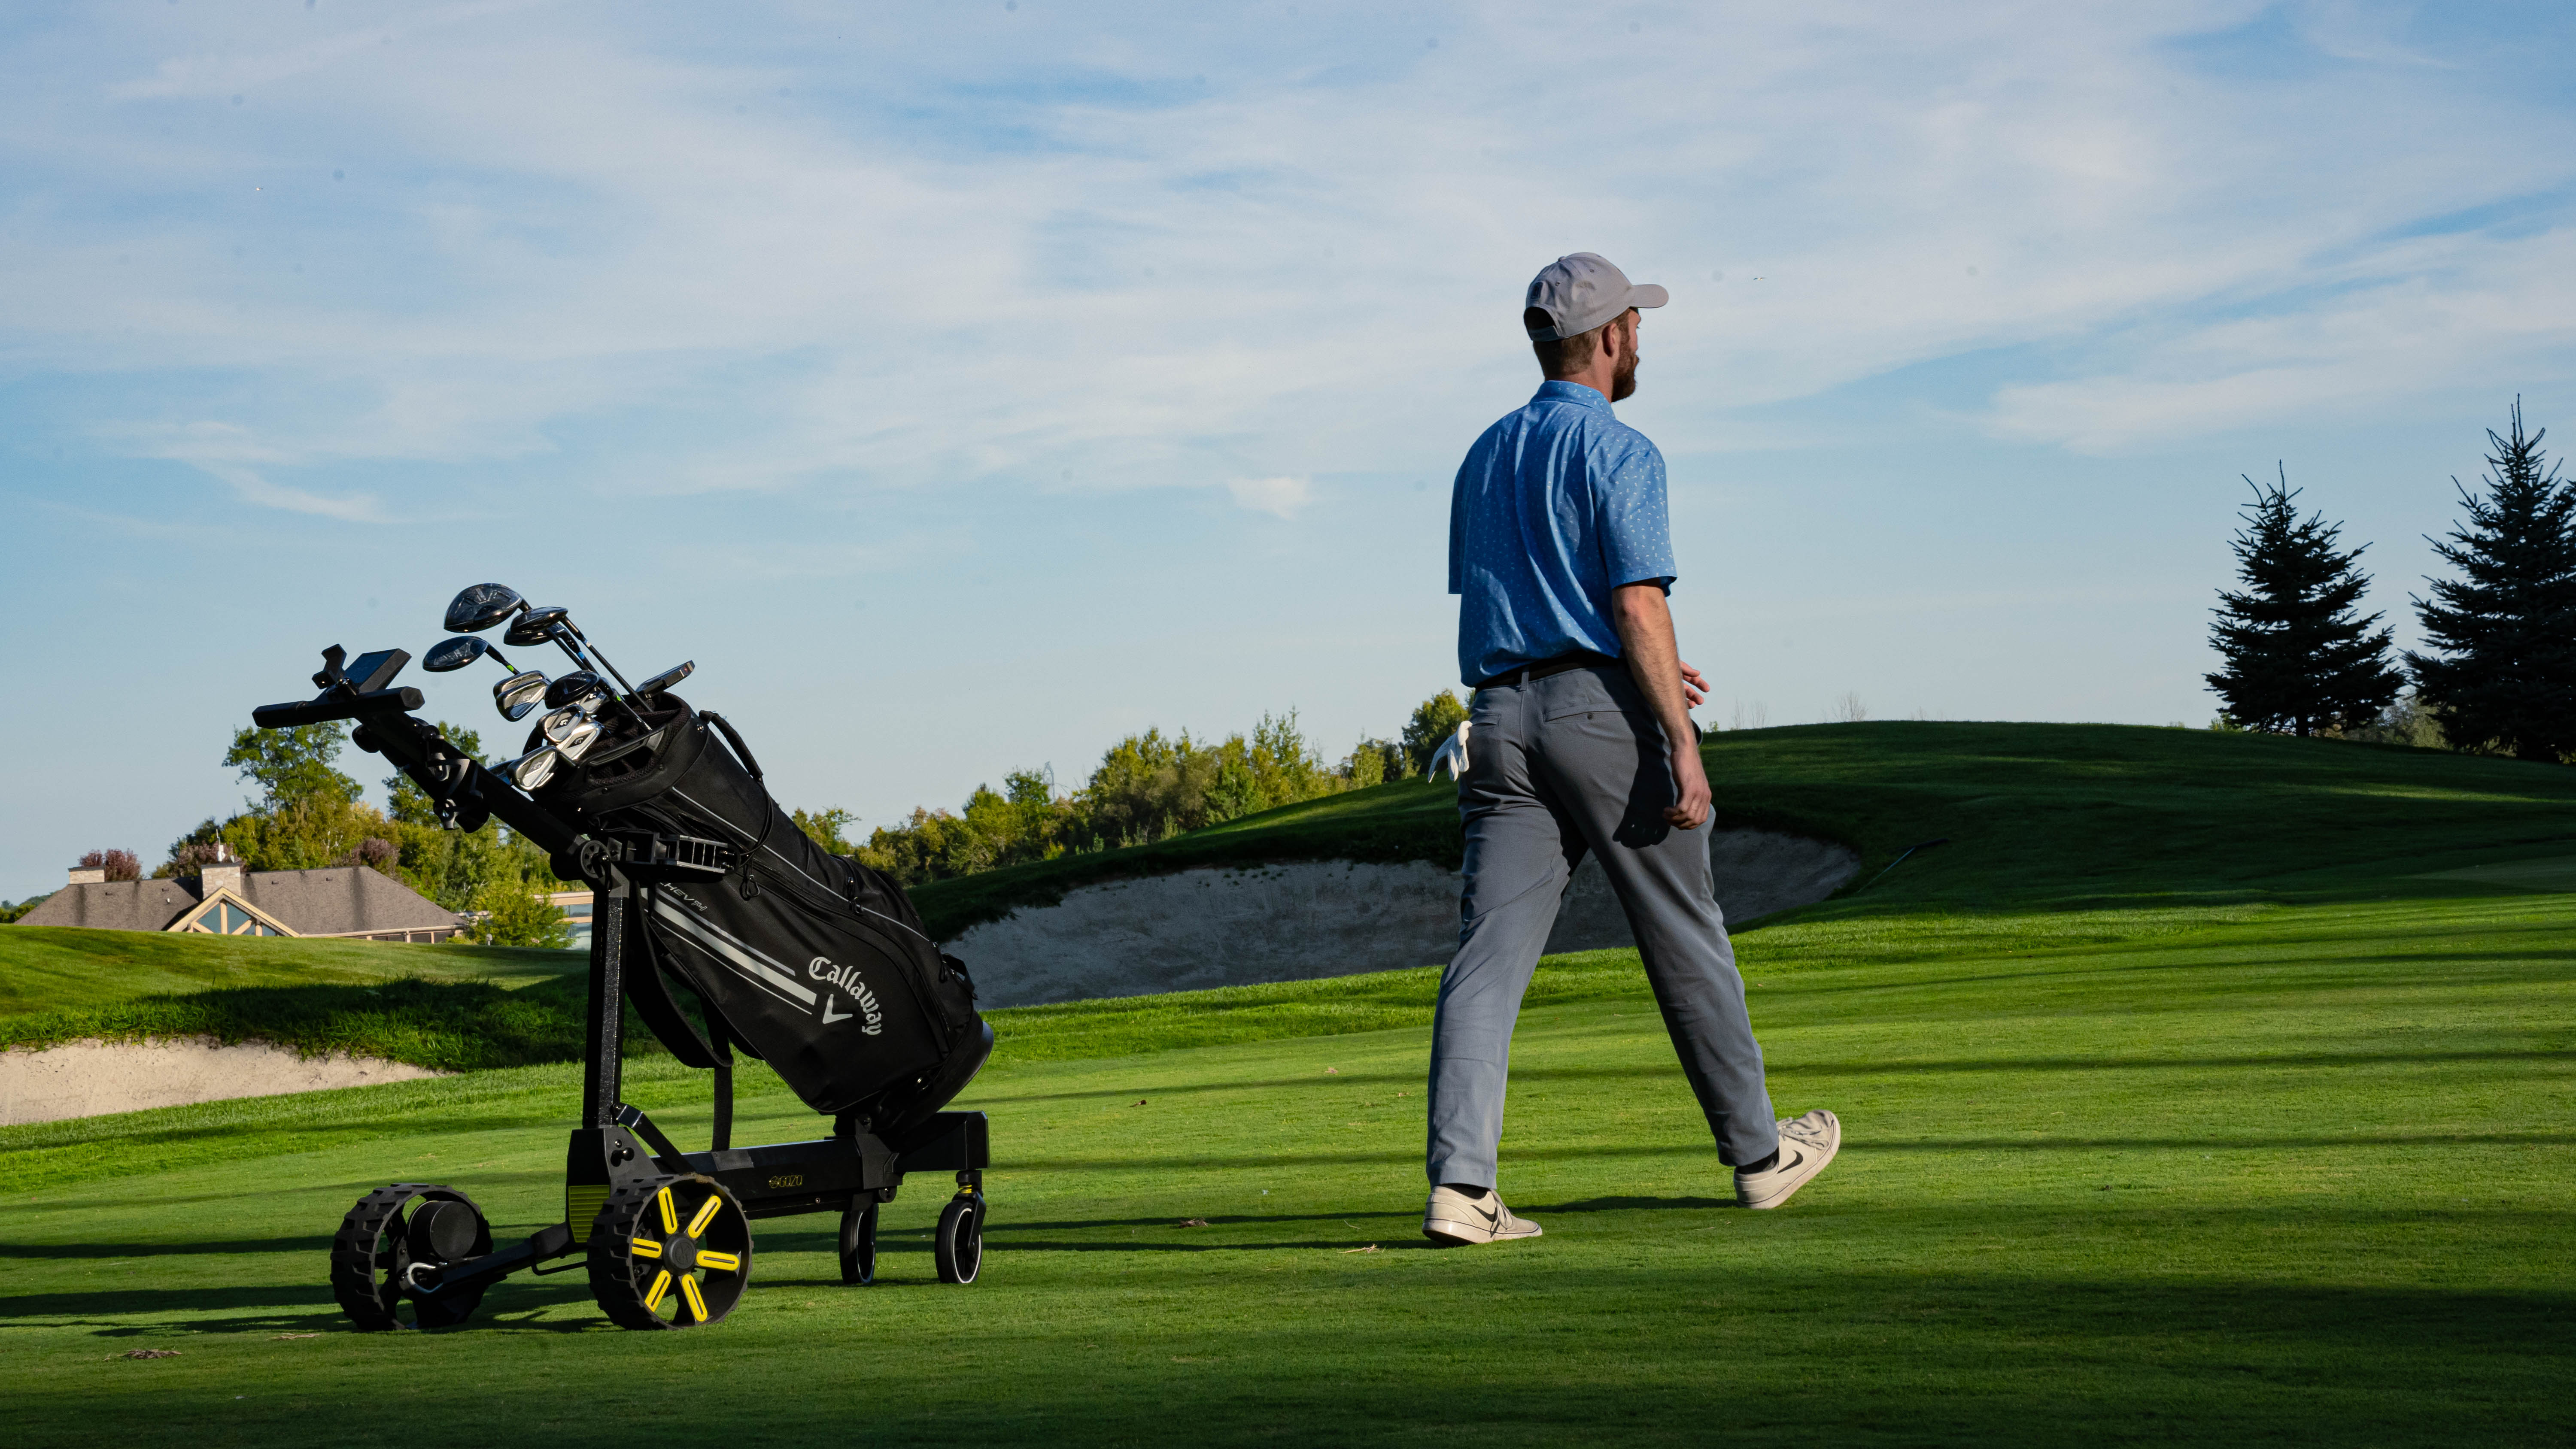
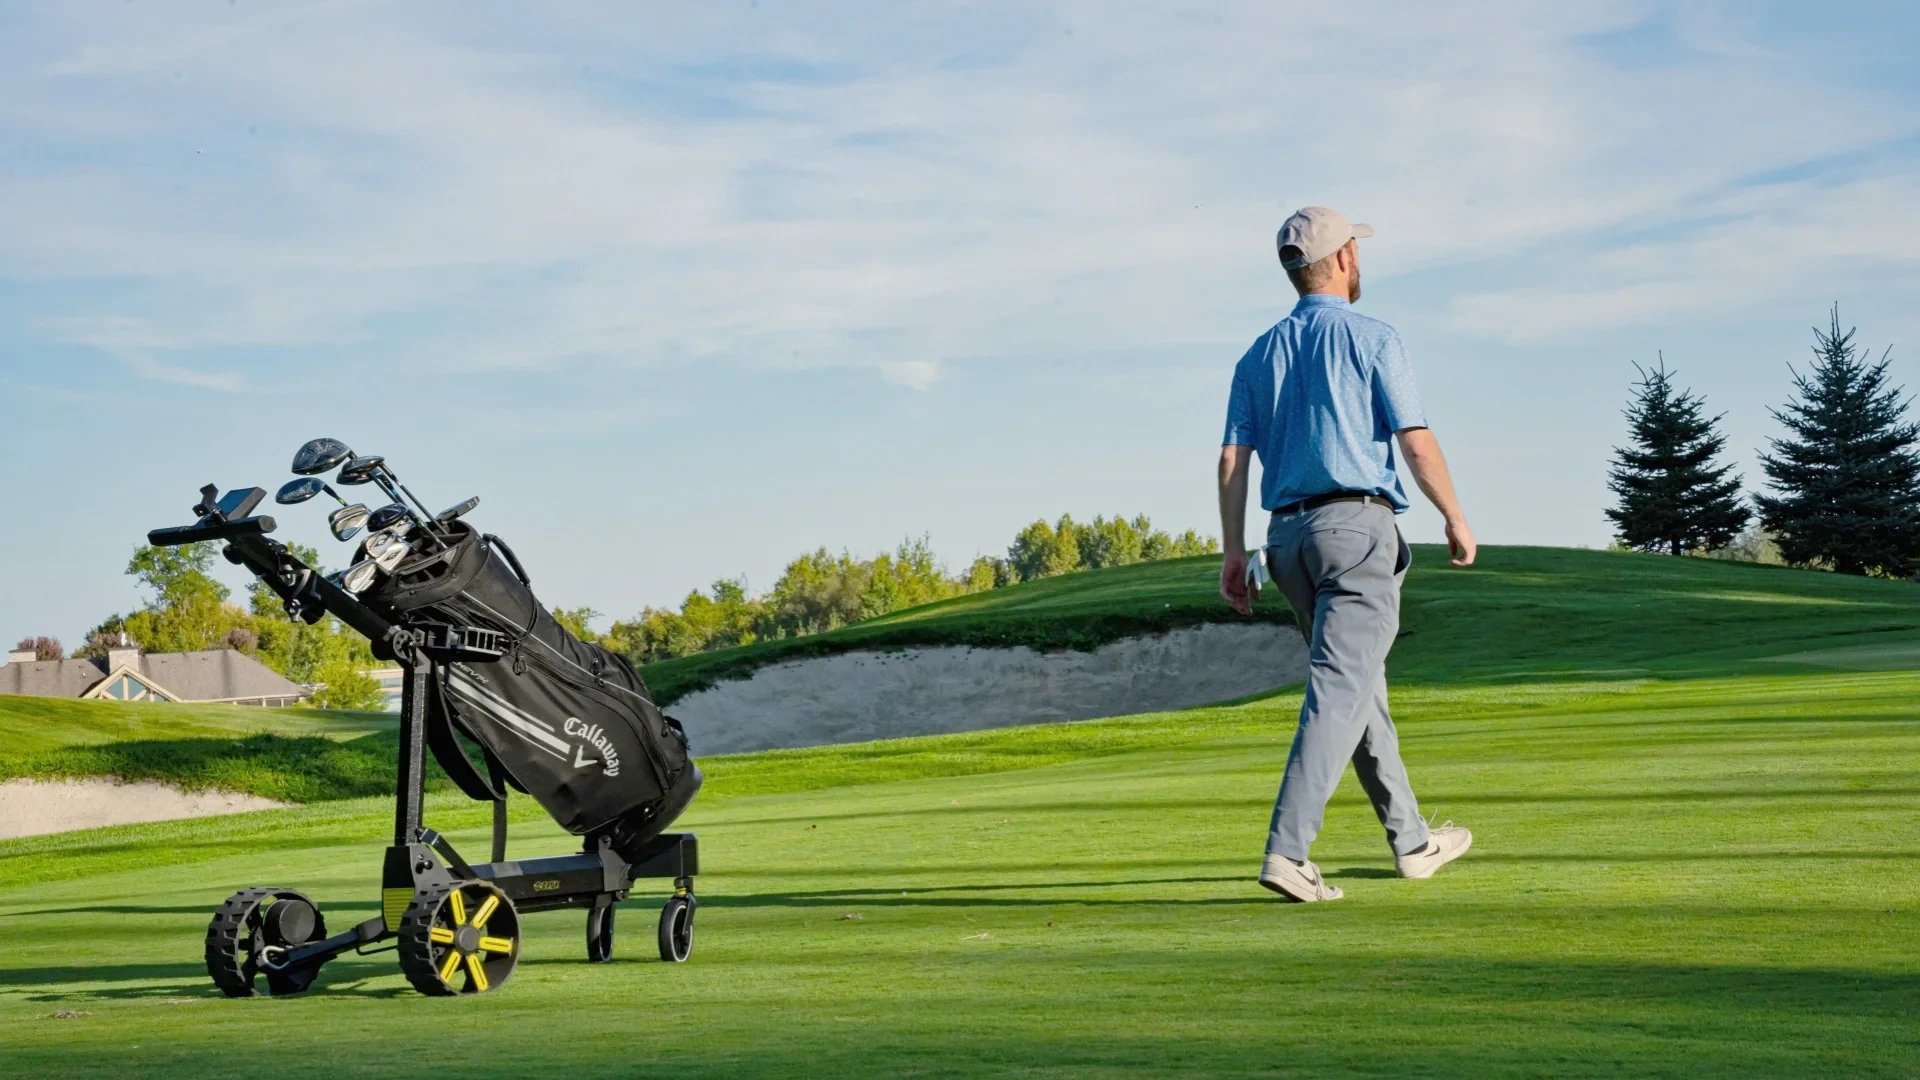
Golf Cart Follow
Autonomous ball cart on the court automatically tracks player positions so you can focus on enjoying the game. Using UWB radar, the system precisely locates players relative to the cart in real time for accurate following—no manual pushing required.

Smart Wheelchair Follow
Smart wheelchair with assistive features that automatically follows the user. Provides independent mobility for users with limited movement, enhancing convenience and independence in daily life.

Smart Suitcase Follow
Smart suitcase that autonomously tracks your movement, freeing your hands and making travel effortless. Achieves precise positioning and stable following via UWB technology.
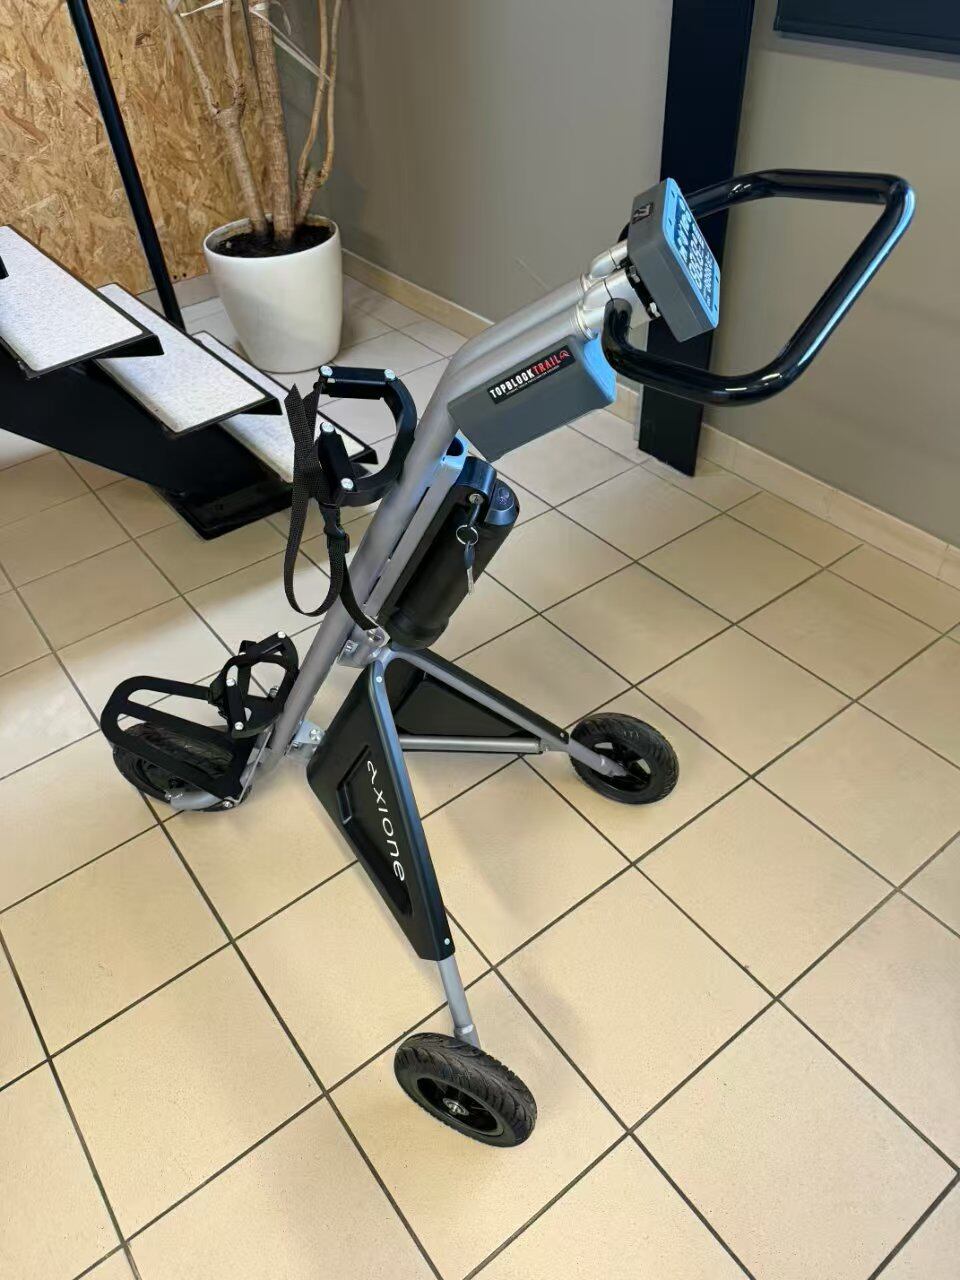
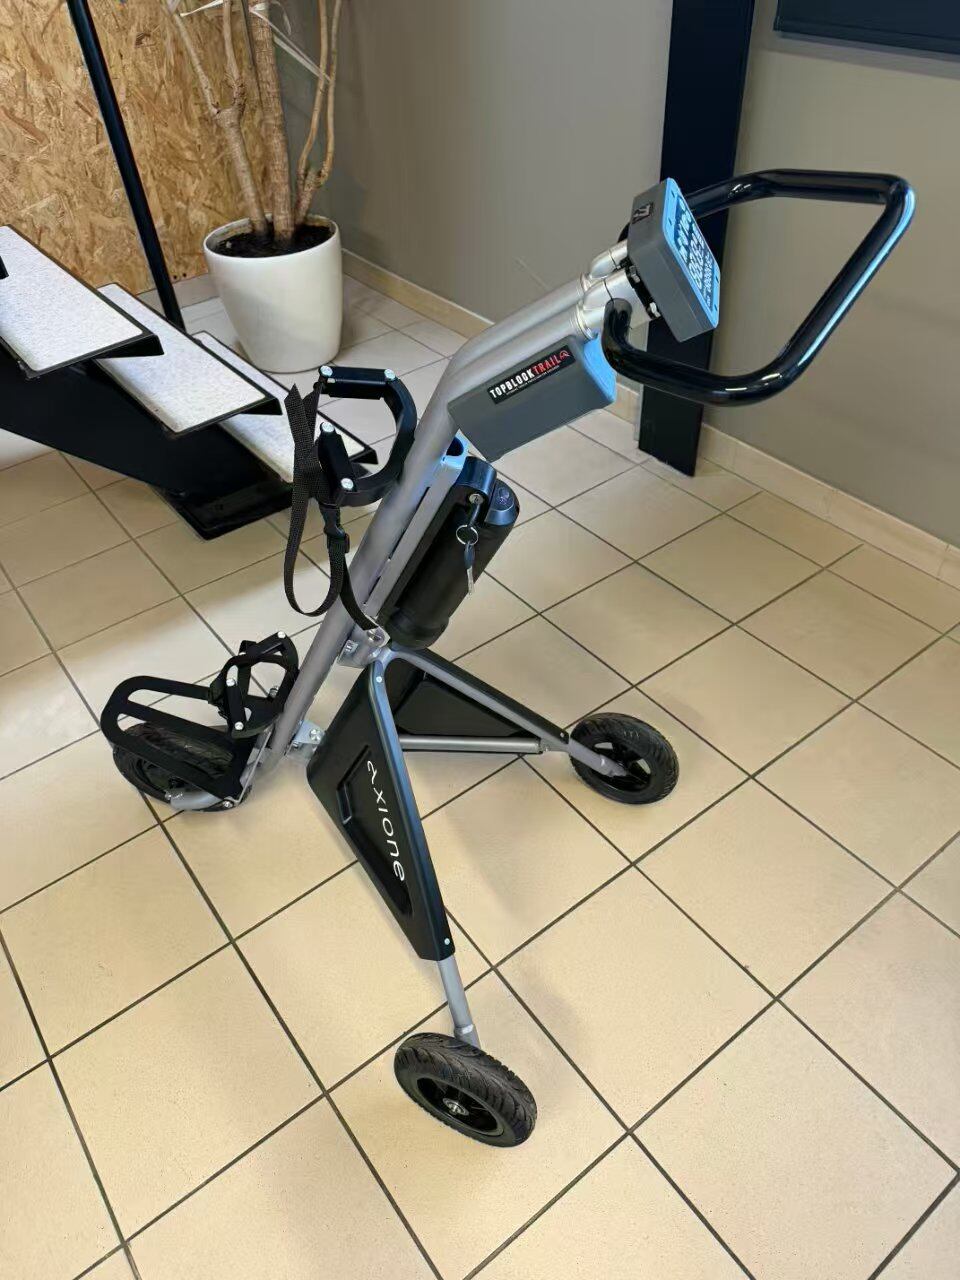
Golf cart follow
Electric golf cart with brushless motor drive and display unit. Lightweight, agile, and smart-assisted design tailored for golf courses to deliver a more effortless and enjoyable playing experience.

Campervan Follow
Electric cargo hauler for outdoor adventures. Auto-follows you on hiking and camping trips, carrying gear and supplies to make your outdoor activities easier.
Follow system components
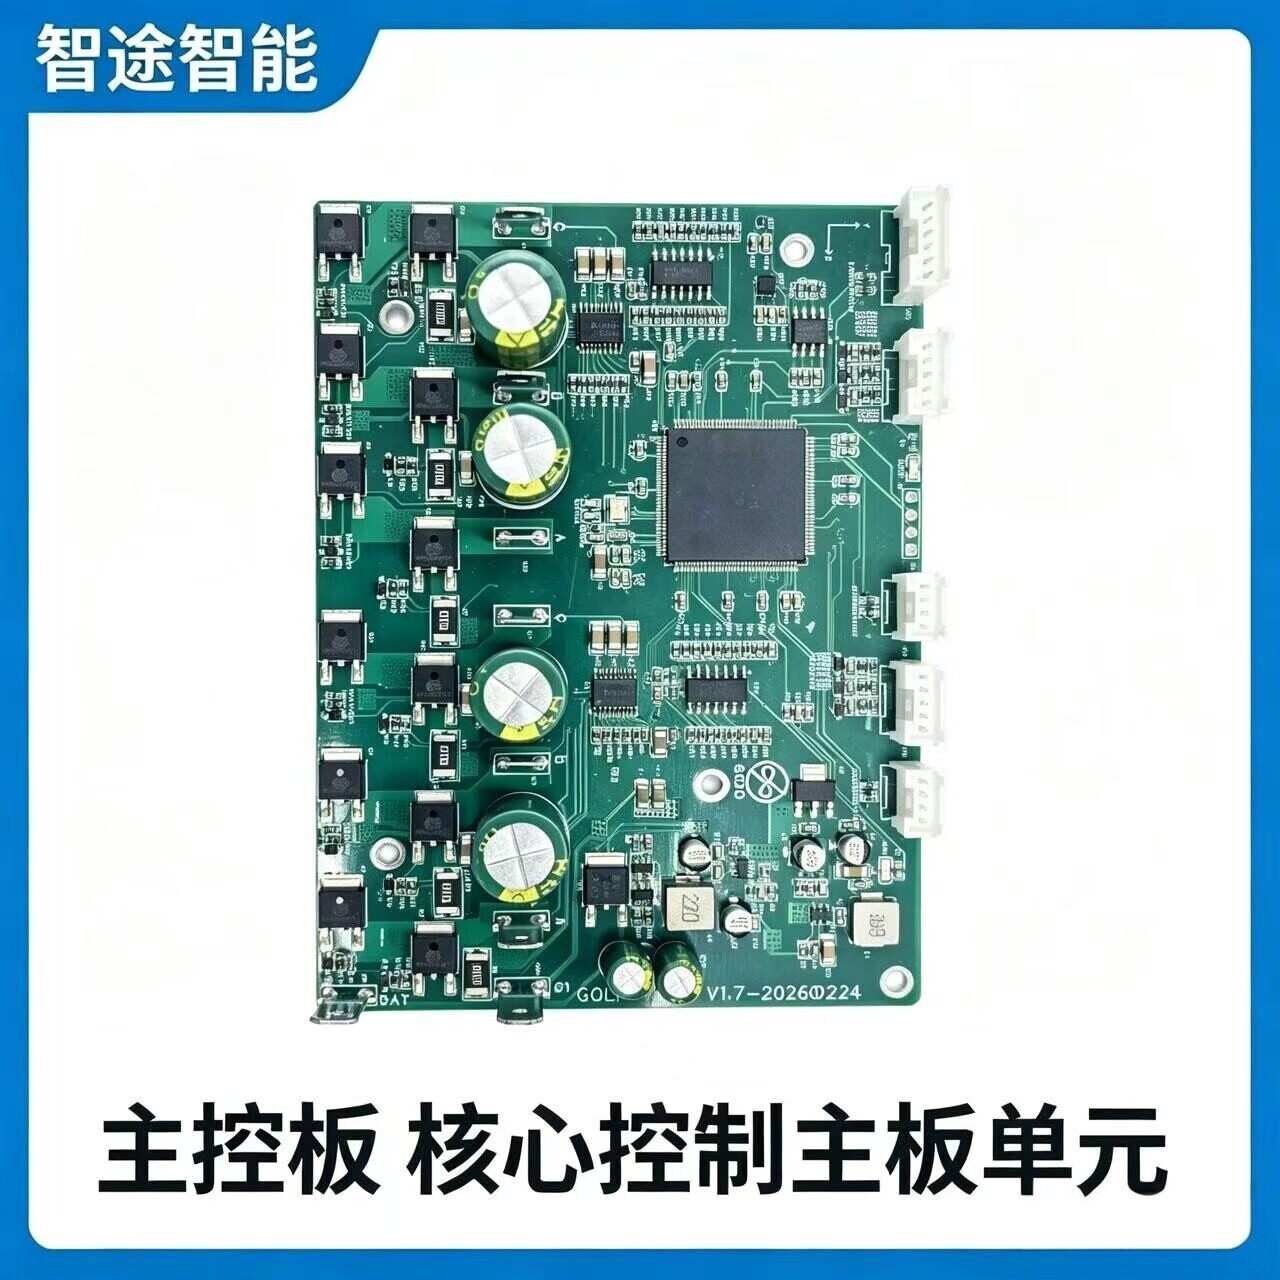
Main Controller
2×450W BLDC motor driver with FOC (Field-Oriented Control) algorithm, built-in 9-axis attitude sensor, supporting tilt detection and overcurrent protection. Supply voltage: DC 15V–29.4V; dual-channel USART communication.
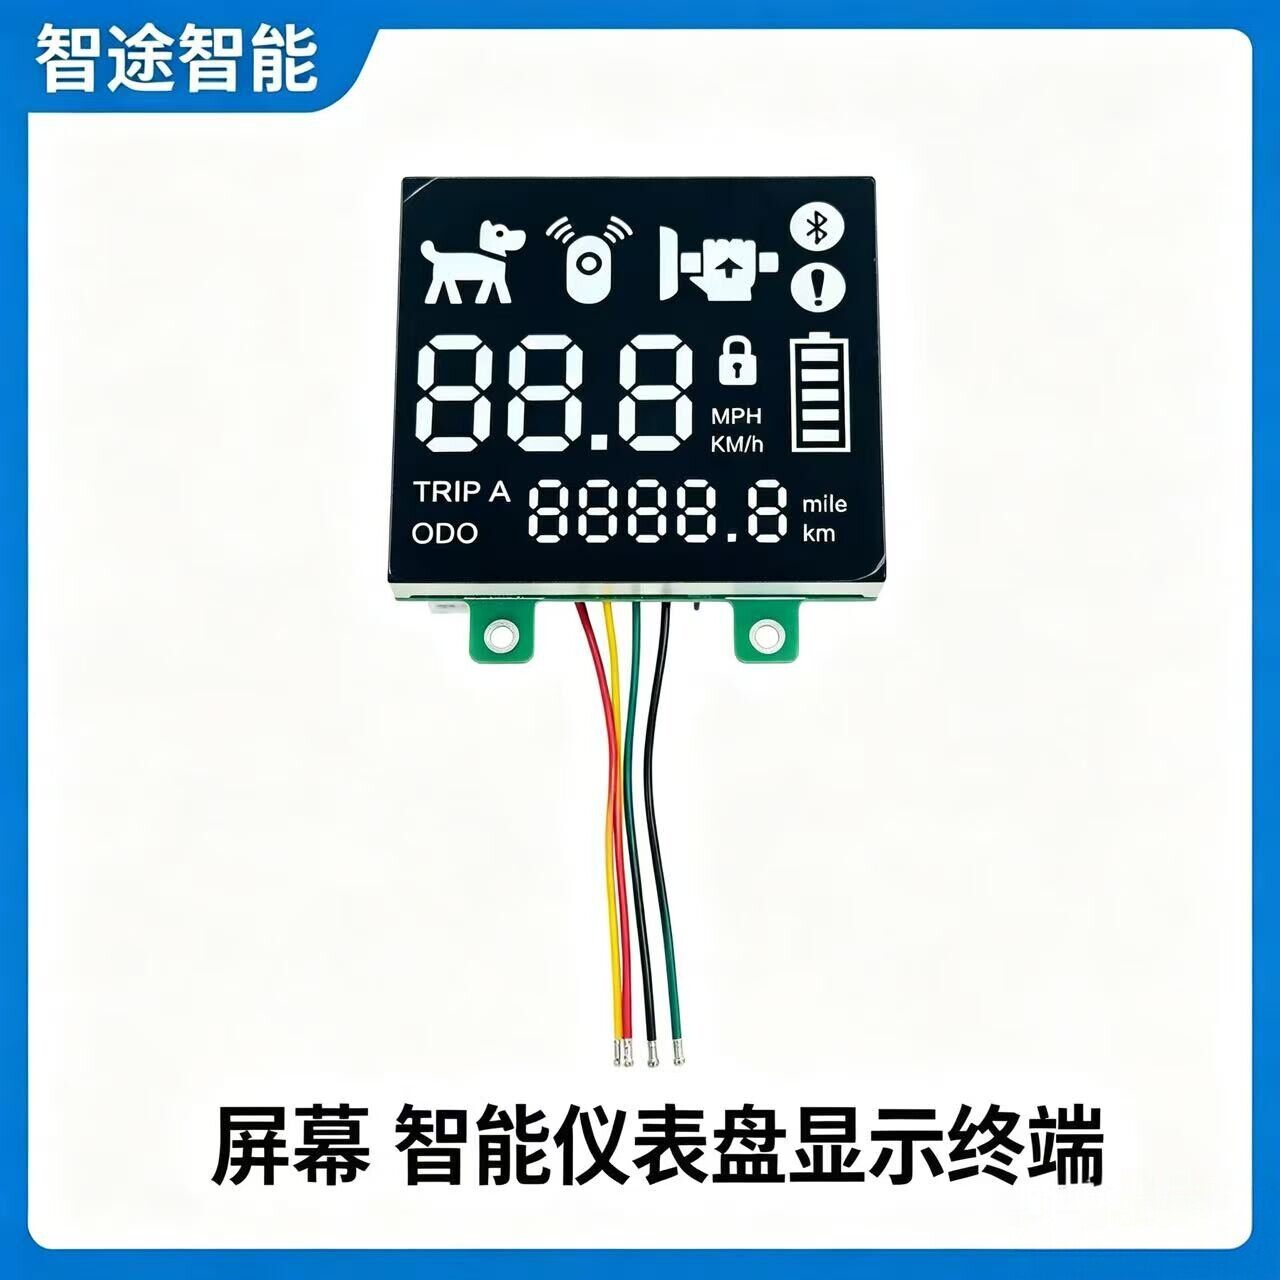
Display Panel
High-visibility display paired with encoder controls for mode switching and speed settings. Clear interface shows system status, enabling real-time parameter adjustments.
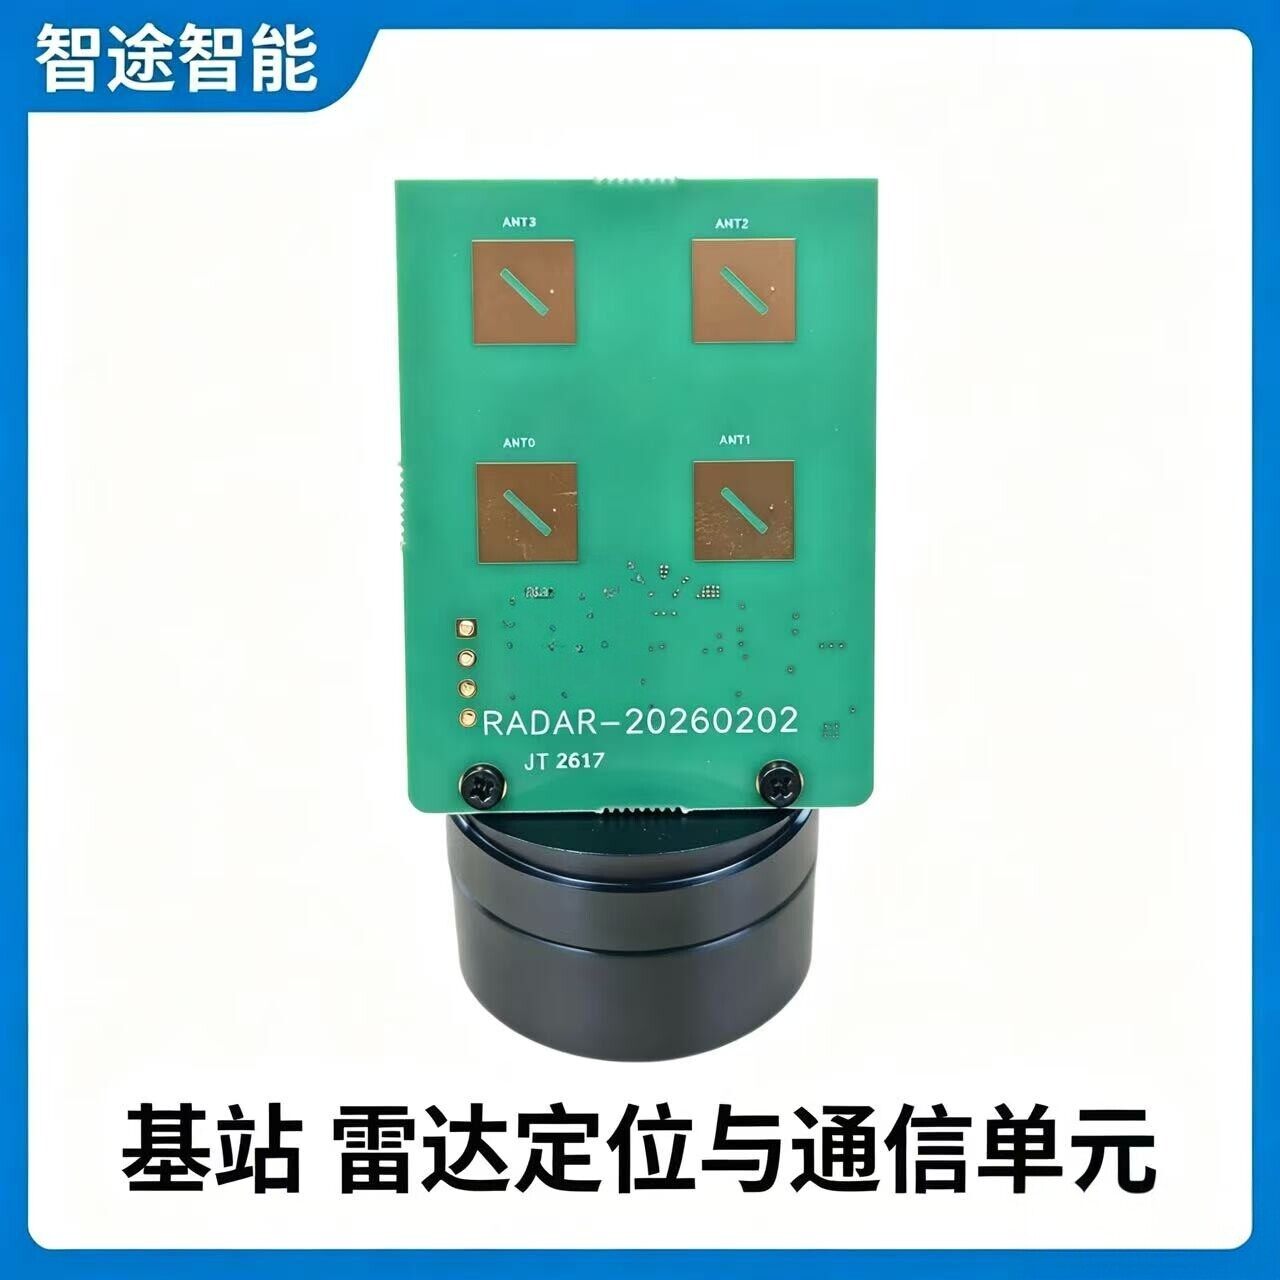
UWB Base Station + Coordination Board
7.9GHz operating frequency, 360° omnidirectional tracking with adjustable range up to 80 meters. Directional antenna ±90° coverage, distance accuracy 10 cm, angle accuracy ±5°, compliant with global frequency regulations. Integrated auxiliary control and connectivity functions for system communication coordination and signal connection.
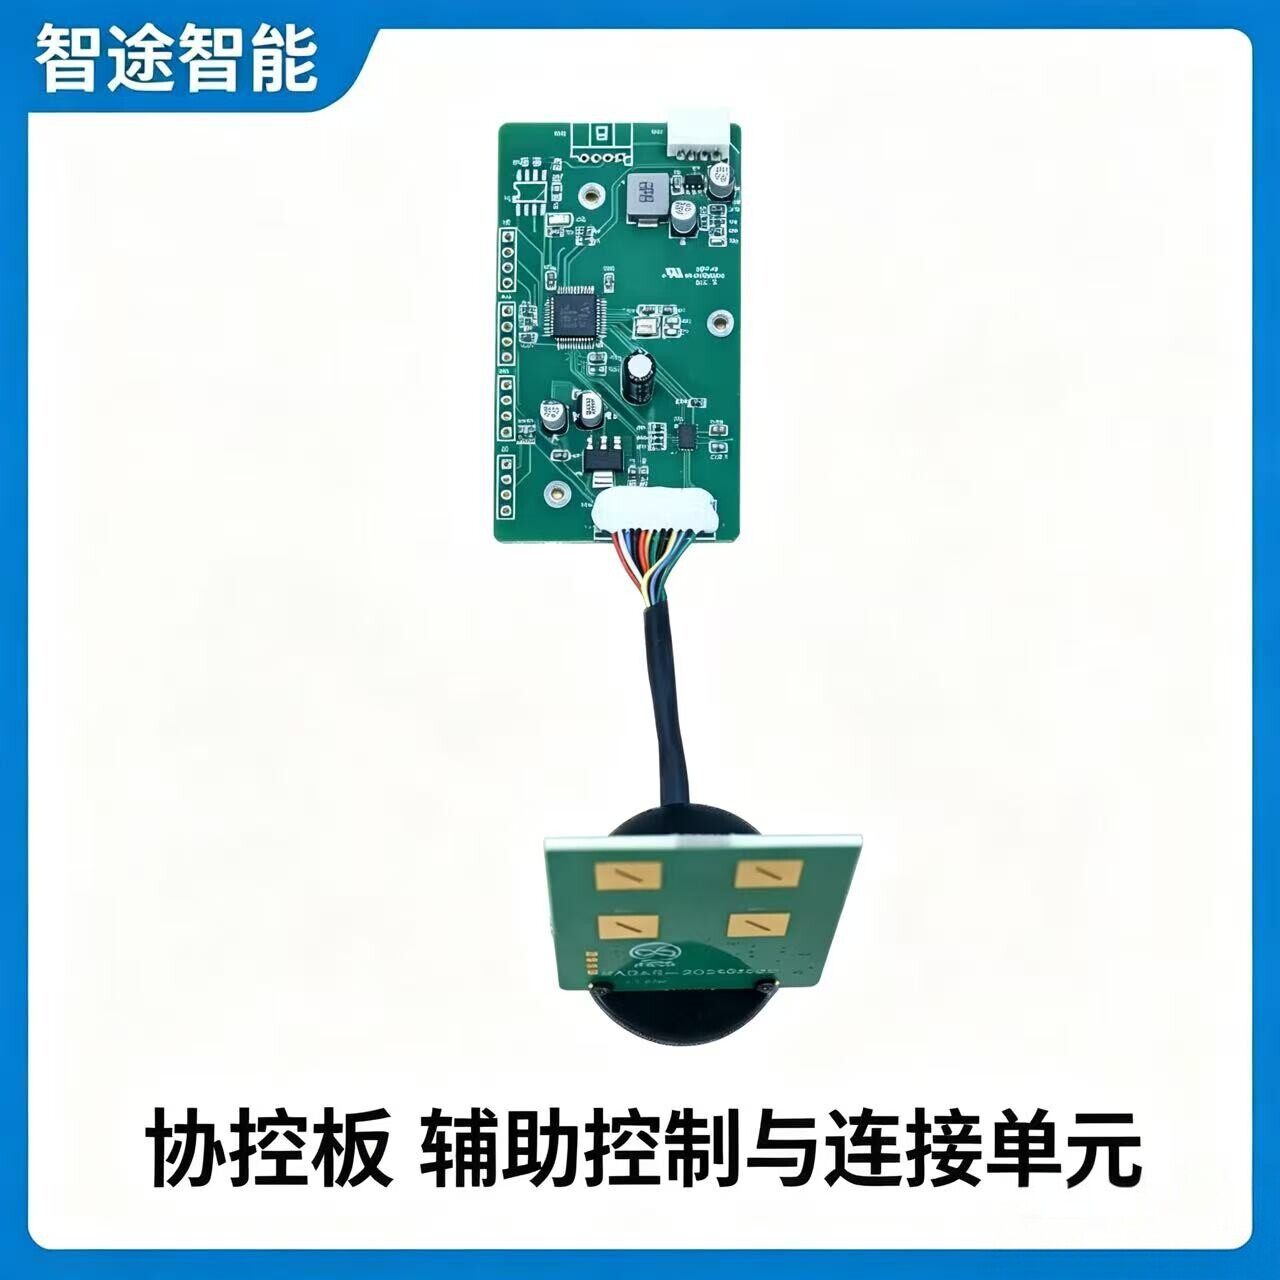
Co-control board
Auxiliary Control and Connection Unit: Manages system communication coordination and signal connections. Supports multi-channel USART for data exchange and collaborative control across modules.
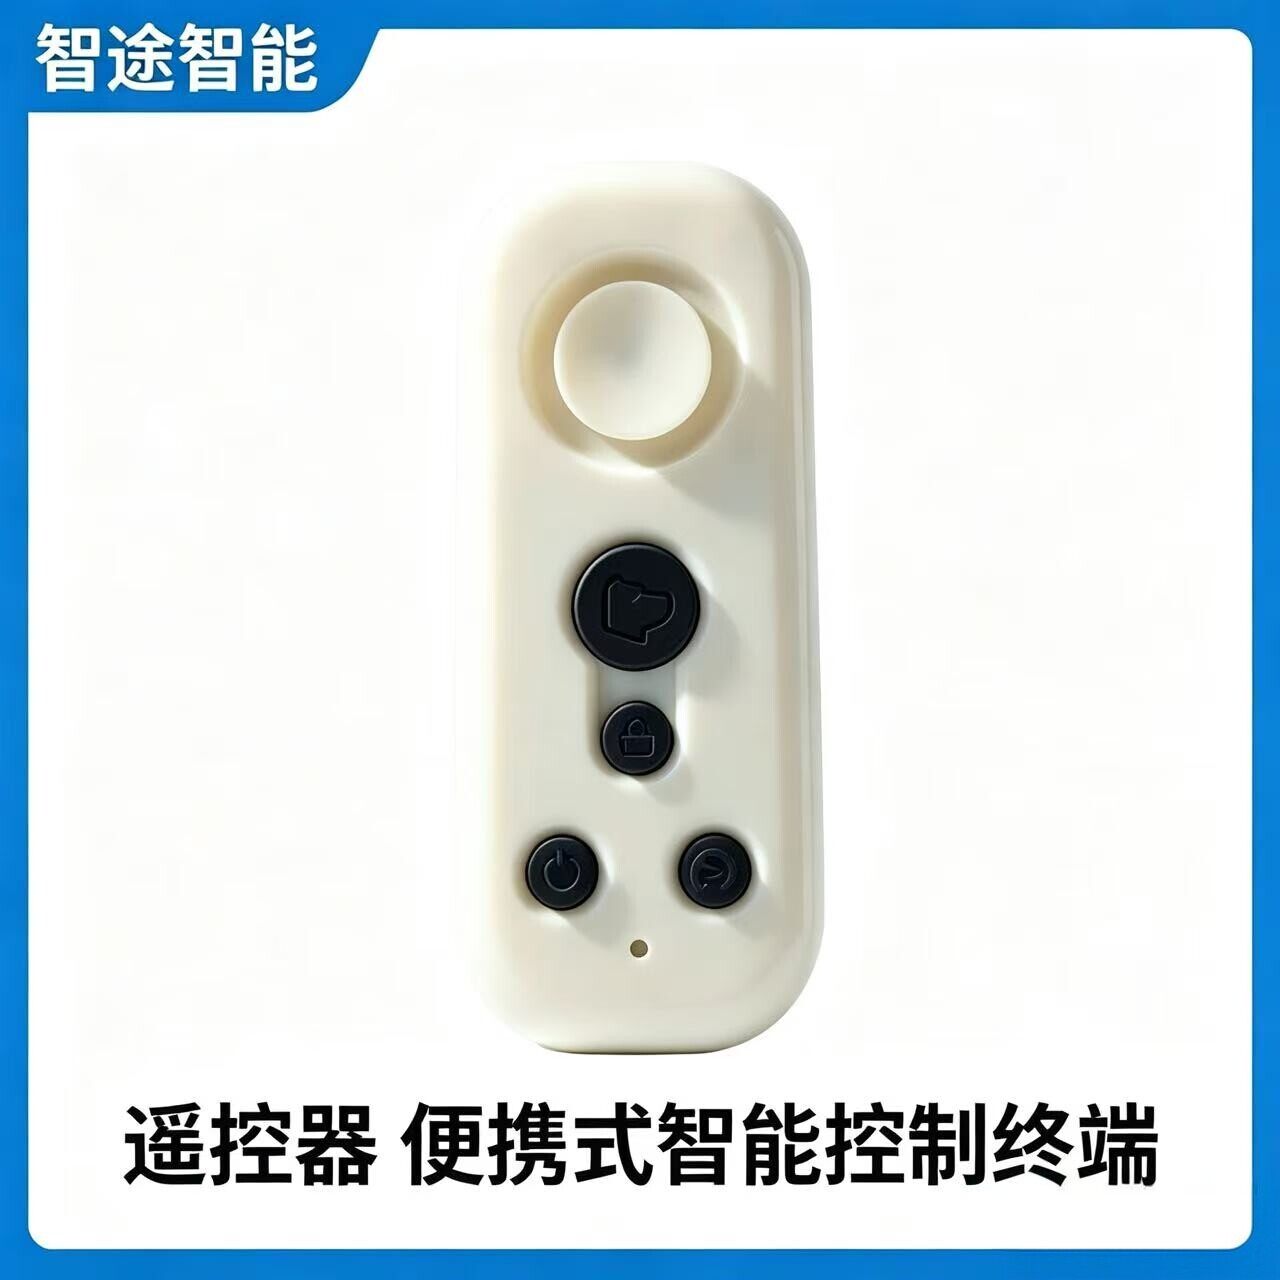
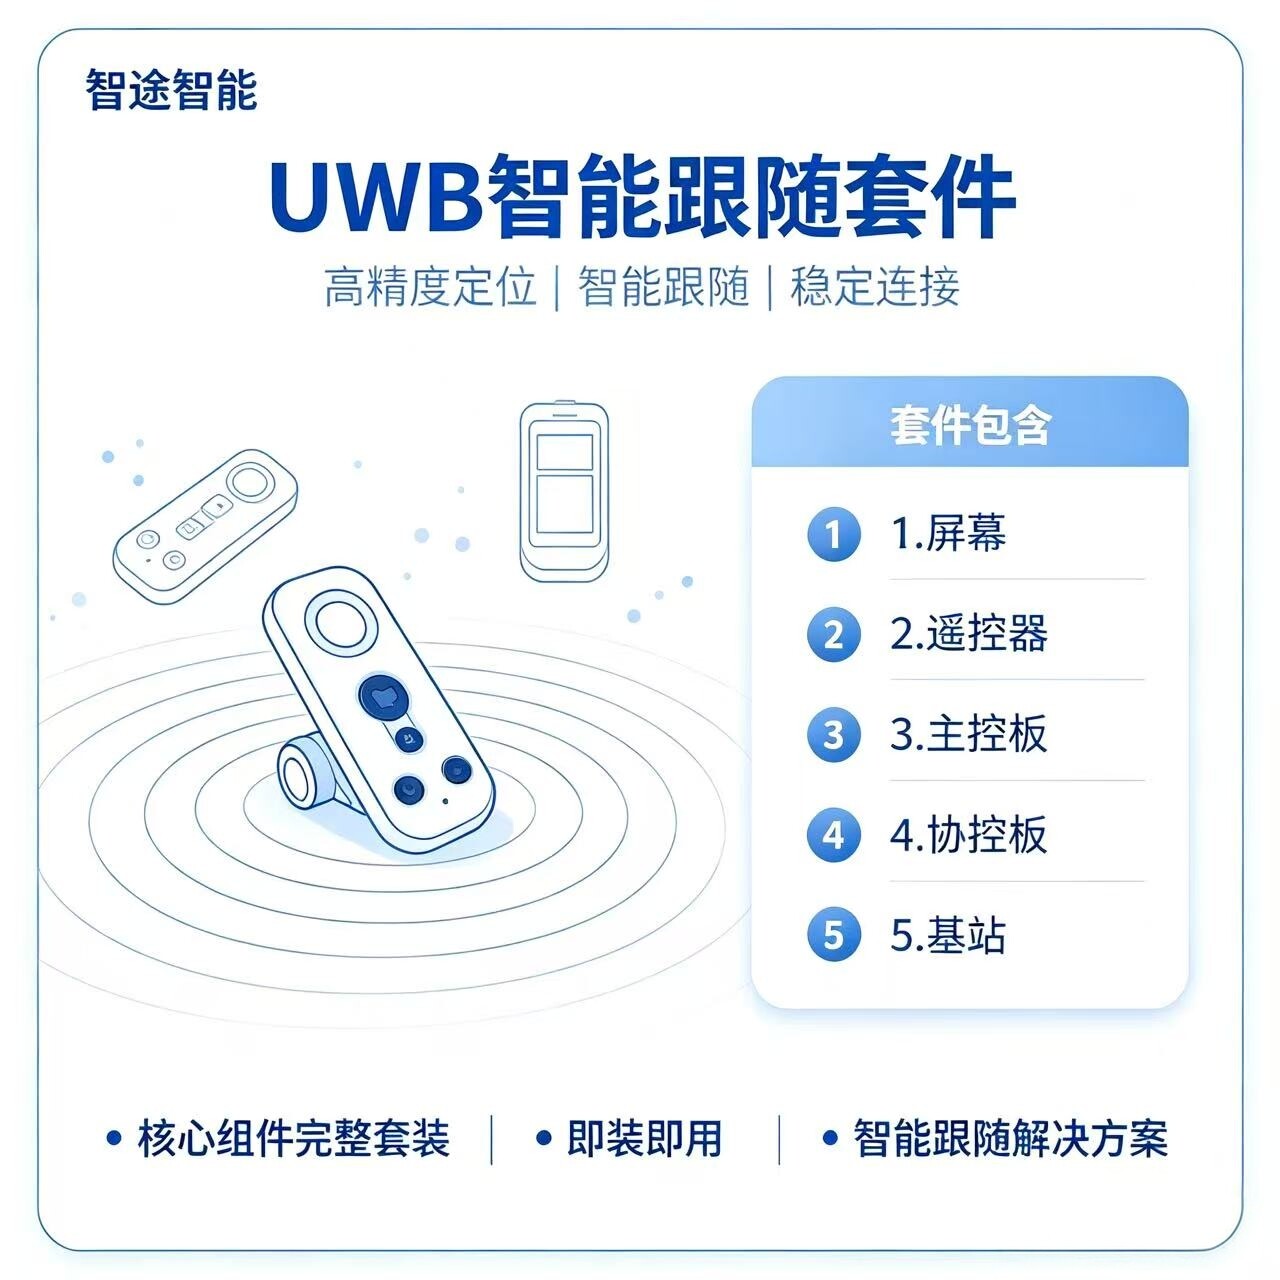
Remote
4 button + 3D joystick design, Type-C charging port, supports multiple modes including follow, lock, and unlock. Ergonomic design for easy operation.
Hardware Module Overview
Main Controller (Bluetooth + MCU Board)
Display (High-Visibility Screen)
UWB Base Station + Coordination Board (Radar Positioning and Communication Unit)
Co-control Unit (Auxiliary Control and Connectivity Unit)
Remote Control (Portable Smart Control Terminal)
Technical Specifications
Motor Control Board Parameters
| Supply Voltage | DC 15V - 29.4V |
| Motor Power | 2 × 45 0W peak |
| Sensor Interface | Digital Hall Sensor |
| Drive Type | FOC (Current Loop + Speed Loop) |
| Pose Sensor | 9 axis (accelerometer + gyroscope + magnetometer) |
| Communication Interface | 2× USART @ 230400 Bps |
| Power Output | 12V @ 1.2A |
UWB Tracking System Parameters
| Operating Frequency | 7.9GHz (Global Compliance) |
| Scope of Work | Up to 80 meters |
| Angle Precision | ±5° |
| Distance Precision | 10 cm |
| Antenna | Direction ±90° |
| Operating Voltage | 5V |
| 360° Follow | Support |
| Communication Method | USART |
Customization Options
High-Power Driver
Custom high-voltage, high-power motor drive solutions for heavy-load applications.
Wireless Integration
Built-in Bluetooth and wireless interfaces for seamless device connectivity.
Single-channel solution
Single-channel drive option: simpler and more cost-effective
Actual Performance
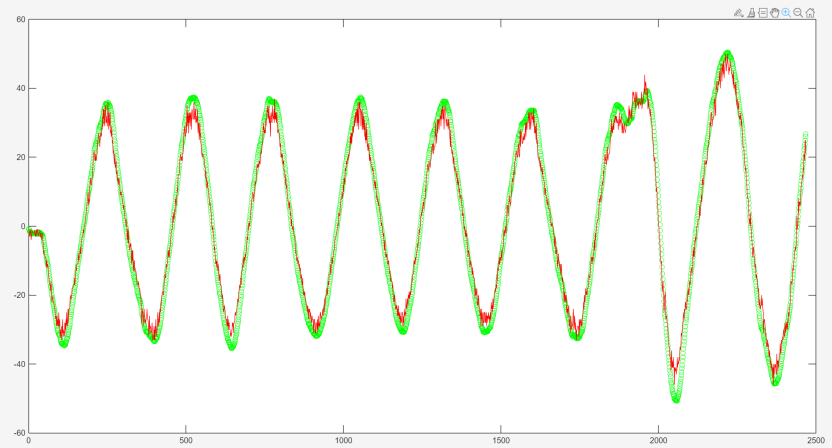
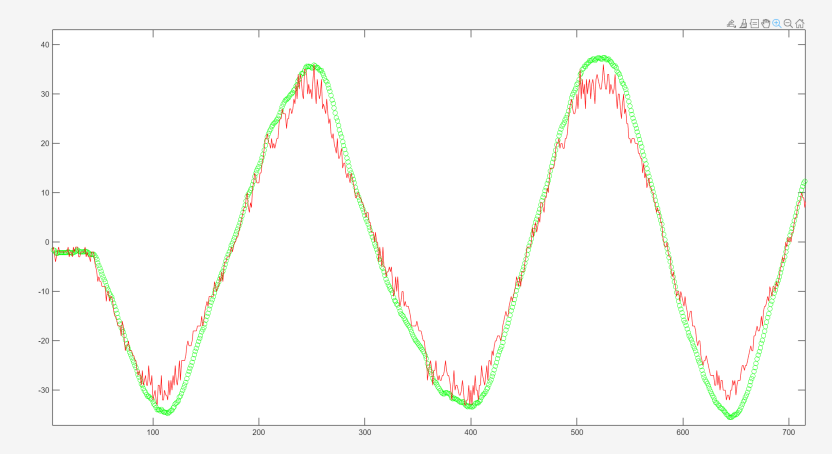
UWB Dynamic Performance
Red indicates the angle before filtering; green shows the filtered angle. The plot demonstrates that the filtered output responds quickly and produces a smooth angle.
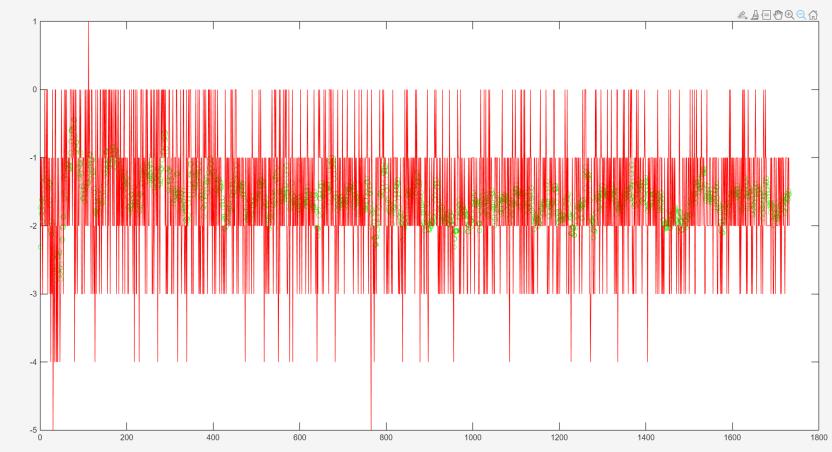
Angle static stability
Low steady-state error, static fluctuation < 2 degrees